
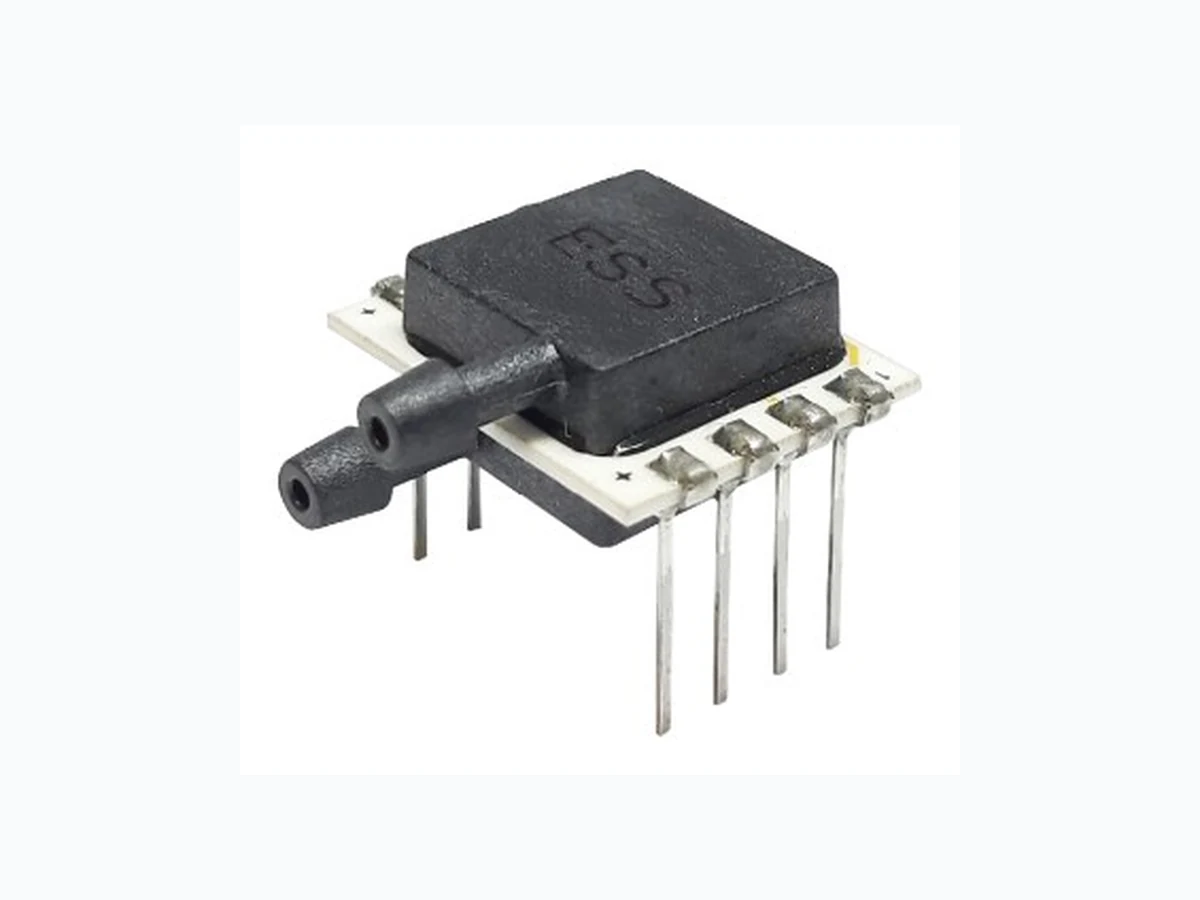
ESCP-BMS1 ES
Document overview
- Manufacturer or author: Provided By www.digicamel.com(FREE DATASHEET DOWNLOAD SITE)
- PDF pages: 23
Technical content
v1.7 Datasheet ESCP-BMS1
- State of the art performance due to MEMS capacitive technology
- Outstanding overpressure tolerance (up to 100x)
- Absolute, differential, gauge operation
- Full scale pressure sensor options from 10 mbar to 11000 mbar
- Temperature sensor: -20oC to +85oC
- Calibrated & temperature compensated output
- I2C, SPI or analog interface
- Excellent accuracy, resolution, long term stability
- Low power consumption
- No external components required Typical Applications Industrial Air Flow Measurement • Air Compressors • Air Movement Control • Actuators • Analytical Instruments • Automated Pneumatic Assembly Equipment • Chemical Analysis Controllers • Factory Automation • Fire Suppression System • Flow Calibrators Gas Chromatography • Gas Flow Instrumentation • Gaseous Leak Detection • Industrial Controls • Industrial Gas Supply • Industrial Pneumatic Devices • Leak Detection • Modulated Furnace Controls • Oxygen Concentrators • Panel Meters • Pressure Switching • Pressure Valves • Process Control Pumps • Remote Monitoring Devices • Robotics • Valves • Vacuum Pump Monitoring • Variable Air Volume (VAV) Control Medical Anesthesia Equipment • Breathalyzers • CPAP Equipment • Drug Dosing Equipment • Hospital Beds • Hospital Gas Supply • Hospital Room Air Pressure • Massage Machines • Medical Instrumentation • Nebulizers • Patient Monitoring Equipment • Respiratory Equipment • Sleep Apnea Equipment • Spirometers • Ventilators • Wound Therapy HVAC Airflow Monitoring • Clogged Filter Detection • Duct Air Flow • Environmental Control Systems • Filter Monitoring • Blocked Filter Detection • Indoor Air Quality Product Summary ES Systems has developed a series of board mountable pressure sensors targeting a variety of markets requiring high resolution and accuracy for absolute, gauge or differential pressure measurements. The ESCP -BMS1 is a MEMS capacitive pressure sensor with state -of-the-art performance. The MEMS pressure sensor die is underpinned by ES ’ innovative SOI -surface micromachining technology. ESCP-BMS1 is an absolute, gauge or differential pressure sensor of ultra high resolution with analog, SPI or I 2C interface. The output is fully calibrated, and temperature compensated based on the internal temperature sensor and the factory calibration coefficients which are stored in the embedded memory. The sensor is ready to be installed directly to the end system without further processing. The total error including repeatability, hysteresis, non -linearity, thermal offset and calibration error between 0oC and 60oC is better than 0.25% FS. Different power modes are available enabling low power operation. The sensor can be configured to provide both high accuracy 32-bit pressure and temperature outputs. ESCP-BMS1 is a silicon capacitive pressure sensor with excellent long -term stability. The sensor is incorporated in a standard 8 -pin DIP package with a single or two pneumatic ports. The top port is the high side and the bottom port is the low side. MEMS Capacitive Pressure & Temperature Sensor for gases. A ll data sheet.com
Total Error Band (TEB) is a single specification that includes all possible sources of error in a pressure measurement. TEB should not be confused with accuracy, which is actually a component of TEB. TEB is the worst error that the sensor could experience. The TEB specification on a datasheet may be confusing. ES Systems uses the TEB specification in its datasheet because it is the most comprehensive measurement of a sensor ’s true accuracy. ES Systems also provides the accuracy specification in order to provide a common comparison with competitors’ literature that does not use the TEB specification. Offset Full Scale Span Pressure Non-Linearity Pressure Hysteresis Noise Pressure Non-Repeatability Thermal Effect on Offset Thermal Effect on Span Thermal Hysteresis Accuracy TEB All Possible Errors Accuracy Performance FS range absolute: 0.5 to 10 bar FS range gauge: 60 to 11000 mbar FS range differential: ±50 to ±1000 mbar 0% FS to 100%FS = ±0.15%FS Total Error Band Performance FS range absolute: 0.5 to 10 bar FS range gauge: 60 to 11000 mbar FS range differential: ±50 to ±1000 mbar 0% FS to 100% FS = ±0.25%FS The figure below, illustrates the accuracy as well as the total error of the pressure measurement of ESCP -BMS1 sensors. 1. Total Error Band A ll data sheet.com
- Absolute Maximum Ratings1 Characteristic Min. Max. Unit Supply voltage (Vsupply) 2.7 3.6 Vdc Voltage on any pin -0.3 3.6 V Current on any pin - 2 mA Burst pressure - 202 bara Storage temperature -20[-4] +85[+185] oC[oF] 1 Absolute maximum ratings are the extreme limits the device will withstand without damage. The electrical and performance characteristics are not guaranteed as the maximum limits are approached, nor will the device necessarily operate as specified at absolute maximum ratings. Prolonged operation at absolute maximum ratings will degrade the device performance
2 For sensors with FS pressure output < 1bara Burst pressure is 5bara
Do not apply mechanical stress to the sensor. Failure to comply with the instructions may result in product damage. CAUTION PRODUCT DAMAGE Do not disassemble these products. Failure to comply with the instructions may result in product damage. 3. Operating Specifications Characteristic Min. Typ. Max. Unit Supply voltage (Vsupply)1 2.7 3.3 3.6 V Supply current Continuous mode Sleep mode 0.5 0.1 mA Output Calibrated Pressure & Temperature - Output Interface I2C, SPI, Analog - Digital bus frequency I2C SPI 100 1000 kHz Analog Output Resistance 220k - - Ohm Start-up time2 - 30 - msec Operating temp. range -20[-4] - +85[+185] oC[oF] Relative humidity (non-condensing) - - 95 % RH I2C/SPI voltage Level Low High %Vsupply Pull up on SDA / MISO / SCL / SCLK / SS 4.7 - - kOhm Media Compatibility - Gases 1The sensor is not reverse polarity protected. Incorrect application of supply voltage or ground to the wrong pin may cause electrical failure. 2After 95% of Vsupply reached. A ll data sheet.com
- Pressure Sensor Specifications 1 The temperature range over which the sensor will produce an output proportional to pressure within the specified performance limits. Note that for valid datasheet values, ambient and medium temperatures must be the same
2 For the 10mbar differential sensor only, effective resolution is 11 bits at 15Hz and 10 bits at 1KHz
3 The maximum deviation from ideal transfer function over the entire compensated temperature and pressure range. Includes all errors due to offset, full scale span, accuracy, thermal effect on offset, thermal effect on span and thermal hysteresis 4 For the 10mbar differential sensor only, TEB is ±2.0 % FSS for 0oC to +60oC and ±2.5 % FSS for –20oC to +85oC 5 The algebraic difference between the output signal measured at the maximum (Pmax) and the minimum (Pmin) limits of the pressure range 6 The maximum deviation in output from a Best Fit Straight Line (BFSL) fitted to the output measured over the pressure range at 21oC [69.8oF]. Includes all errors due to pressure non-linearity, pressure hysteresis, non-repeatability and noise 7 For the 10mbar differential sensor only, accuracy is ±1.5 % FSS
8 Accelerated Life Test Profile: 100hours at 90oC
- Temperature Sensor Operating Specifications Characteristic Unit Min. Typ. Max. Full Scale range -20[-4] - +85[+185] oC[oF] Accuracy - 0.5 - oC Resolution 14 - - bits Output Rate - 250 - msec Characteristic Absolute Gauge Differential Unit Pressure Range 200 - 10000 0 - 11000 -1000 - 1000 mbar Comp. temp range1 Option 01 Option 02 0[32] -20[-4] +60[+140] +85[+185] 0[32] -20[-4] +60[+140] +85[+185] 0[32] -20[-4] +60[+140] +85[+185] oC[oF] Effective Resolution Response Time (15Hz) Response Time (1KHz) 152 112 bits Total Error Band3 0 to +60oC -20 to +85oC ±0.25 ±0.35 ±0.25 ±0.35 ±0.254 ±0.354 FSS5 Long term stability8 - - ±0.25 - - ±0.25 - - ±0.25 %FSS Pressure Type Description Absolute Output is proportional to the difference between applied pressure and vacuum pressure Gauge Output is proportional to the difference between applied pressure and ambient pressure Differential Output is proportional to the difference between the pressures applied to each port (P1 - P2) 4. Sensor Pressure Types A ll data sheet.com
Over Pressure1 Burst Pressure2 Common Mode Pressure3 Pmin Pmax Port1 (P1) Port 2 (P2) Port1 (P1) Port 2 (P2) Absolute 00500MA 200 500 mbara 4000 - 4000 - - 01000MA 200 1000 mbara 4000 - 4000 - - 01250MA 200 1250 mbara 4000 - 4000 - - 02000MA 200 2000 mbara 4000 - 4000 - - 05000MA 200 5000 mbara 20000 - 20000 - - 10000MA 200 10000 mbara 20000 - 20000 - - Gauge 00060MG 0 60 mbarg 1000 - 5000 - - 00100MG 0 100 mbarg 1000 - 5000 - - 00160MG 0 160 mbarg 5000 - 5000 - - 00250MG 0 250 mbarg 5000 - 5000 - - 00400MG 0 400 mbarg 5000 - 5000 - - 00600MG 0 600 mbarg 4000 - 21000 - - 01500MG 0 1500 mbarg 4000 - 21000 - - 05500MG 0 5500 mbarg 21000 - 21000 - - 07000MG 0 7000 mbarg 21000 - 21000 - - 11000MG 0 11000 mbarg 21000 - 21000 - - Differential 00010MD -10 10 mbarg 1000 1000 5000 2500 4000 00050MD -50 50 mbarg 1000 1000 5000 2500 4000 00100MD -100 100 mbarg 1000 1000 5000 2500 4000 00150MD -150 150 mbarg 5000 2500 5000 2500 4000 00200MD -200 200 mbarg 5000 2500 5000 2500 4000 00250MD -250 250 mbarg 5000 2500 5000 2500 4000 00500MD -500 500 mbarg 5000 2500 5000 2500 4000 00750MD -750 750 mbarg 4000 2500 21000 2500 10000 01000MD -1000 1000 mbarg 4000 2500 21000 2500 10000 1 The maximum pressure which may safely be applied to the product for it to remain in specification once pressure is returned to the operating pressure range. Exposure to higher pressures may cause permanent damage to the product. Unless otherwise specified this applies to all available pressure ports at any temperature with the operating temperature range 7. Pressure Range Specifications (mbar) A ll data sheet.com
- Pressure Range Specifications (kPa) Pressure Range Pressure Range Unit Over Pressure1 Burst Pressure2 Common Mode Pressure3 Pmin Pmax Port1 (P1) Port 2 (P2) Port1 (P1) Port 2 (P2) Absolute 00050KA 20 50 kPaA 400 - 400 - - 00100KA 20 100 kPaA 400 - 400 - - 00125KA 20 125 kPaA 400 - 400 - - 00200KA 20 200 kPaA 400 - 400 - - 00500KA 20 500 kPaA 2000 - 2000 - - 01000KA 20 1000 kPaA 2000 - 2000 - - Gauge 00006KG 0 6 kPaG 100 - 500 - - 00010KG 0 10 kPaG 100 - 500 - - 00016KG 0 16 kPaG 500 - 500 - - 00025KG 0 25 kPaG 500 - 500 - - 00040KG 0 40 kPaG 500 - 500 - - 00060KG 0 60 kPaG 400 - 2100 - - 00150KG 0 150 kPaG 400 - 2100 - - 00550KG 0 550 kPaG 2100 - 2100 - - 00700KG 0 700 kPaG 2100 - 2100 - - 01100KG 0 1100 kPaG 2100 - 2100 - - Differential 00001KD -1 1 kPaG 100 100 500 250 400 00005KD -5 5 kPaG 100 100 500 250 400 00010KD -10 10 kPaG 100 100 500 250 400 00015KD -15 15 kPaG 500 250 500 250 400 00020KD -20 20 kPaG 500 250 500 250 400 00025KD -25 25 kPaG 500 250 500 250 400 00050KD -50 50 kPaG 500 250 500 250 400 00075KD -75 75 kPaG 400 250 2100 250 1000 00100KD -100 100 kPaG 400 250 2100 250 1000 2 The maximum pressure that may be applied to the specified port (P1 or P2) of the product without causing escape of pressure media. Product should not be expected to function after exposure to any pressure beyond the burst pressure A ll data sheet.com
- Pressure Range Specifications (psi) Pressure Range Pressure Range Unit Over Pressure1 Burst Pressure2 Common Mode Pressure3 Pmin Pmax Port1 (P1) Port 2 (P2) Port1 (P1) Port 2 (P2) Absolute 00010PA 2.9 10 psia 58 - 58 - - 00015PA 2.9 15 psia 58 - 58 - - 00020PA 2.9 20 psia 58 - 58 - - 00030PA 2.9 30 psia 58 - 58 - - 00075PA 2.9 75 psia 290 - 290 - - 00145PA 2.9 145 psia 290 - 290 - - Gauge 00001PG 0 1 psig 14.5 - 14.5 - - 00002PG 0 2 psig 14.5 - 14.5 - - 00003PG 0 3 psig 72.5 - 72.5 - - 00004PG 0 4 psig 72.5 - 72.5 - - 00005PG 0 5 psig 72.5 - 72.5 - - 00010PG 0 10 psig 58 - 58 - - 00020PG 0 20 psig 58 - 58 - - 00080PG 0 80 psig 304.6 - 304.6 - - 00100PG 0 100 psig 304.6 - 304.6 - - 00160PG 0 160 psig 304.6 - 304.6 - - Differential 00001PD -1 1 psig 14.5 14.5 72.5 36.3 58 00002PD -2 2 psig 14.5 14.5 72.5 36.3 58 00003PD -3 3 psig 14.5 14.5 72.5 36.3 58 00004PD -4 4 psig 72.5 36.3 72.5 36.3 58 00005PD -5 5 psig 72.5 36.3 72.5 36.3 58 00006PD -6 6 psig 72.5 36.3 72.5 36.3 58 00007PD -7 7 psig 72.5 36.3 72.5 36.3 58 00010PD -10 10 psig 58 36.3 304.6 36.3 145 00015PD -15 15 psig 58 36.3 304.6 36.3 145 3 Common mode pressure: The maximum pressure that can be applied simultaneously to both ports of a differential pressure sensor without causing changes in specified performance. Note that pressure should firstly be applied to (P1). A ll data sheet.com
Pressure Port1 (P1) Dry Gas Pressure Port2 (P2) Dry Gas Ports and covers Liquid Crystal Polymer Substrate Alumina Ceramic Al203 Adhesives Epoxy or silicone based Epoxy or silicone based Electronic components Silicon, glass, solder, gold, aluminum, ceramic, silver Silicon 8. Wetted Matterials1
1 Contact ES Systems Customer Service for detailed material information
Vibration 15g, 10Hz to 2 kHz Shock 100g, 6ms duration ESD ESD JS-001-2014 HBM ±1kV Shelf Life 20 years Life1 1 million pressure cycles minimum Soldering time and temperature: Lead solder temperature (DIP) 4sec. max @ 250oC [482oF] 10. Environmental Specifications
1 Life may vary depending on specific application in which the sensor is used
Output PIN1 PIN2 PIN3 PIN4 PIN5 PIN6 PIN7 PIN8 I2C Int Sel1 VDD SDA SCL NC2 NC NC GND SPI Int Sel1 VDD MOSI SCLK NC CS MISO GND Analog NC VDD NC NC Aout NC NC GND 1 Interface select. Tie to VDD for I2C communication or GND for SPI communication
2 Do not Connect
- Pinouts A ll data sheet.com
- Data & Register Description The sensor outputs a 32 bit calibrated pressure output of the pressure range in calibration units. The 32 bit register is a signed fixed point integer and is organized as follows. The 32 bit register consists of four 8 bit registers in consecutive addresses. The calibrated pressure value starts at address 0x40 and ends at address 0x43. The sensor allows for address autoincrement hence the user only needs to request data from the initial address (in this case 0x40) and then perform continuous reads for the remaining bytes of the 32 bit value. Data comes most significant bit first, least significant byte first (little endian). The calibrated temperature value starts at address 0x44 and ends at address 0x47. The same as pressure value data comes out most significant bit first, least significant byte first (little endian). The register organization is presented below: ADDRESS REGISTER NAME TYPE DEFAULT VALUE (Hex) MNEMONIC Calibrated Pressure Byte 1 R Variable CAL_PRESS_DATA[7:0] 0x40 Calibrated Pressure Byte 2 R Variable CAL_PRESS_DATA[15:8] Calibrated Pressure Byte 3 R Variable CAL_PRESS_DATA[23:16] Calibrated Pressure Byte 4 R Variable CAL_PRESS_DATA[31:24] ADDRESS REGISTER NAME TYPE DEFAULT VALUE (Hex) MNEMONIC Calibrated Temperature Byte 1 R Variable CAL_TEMP_DATA[7:0] 0x44 Calibrated Temperature Byte 2 R Variable CAL_TEMP_DATA[15:8] Calibrated Temperature Byte 3 R Variable CAL_TEMP_DATA[23:16] Calibrated Temperature Byte 4 R Variable CAL_TEMP_DATA[31:24] To convert reading into temperature: To convert reading into pressure: Calibrated Temperature: Calibrated Pressure: A ll data sheet.com
Data Register Reading Process The process that the user must follow to read the data from BMS1 device is very similar in both I2C and SPI interfaces. As described in the previous sections the user must first address the register to be read and then read sequentially all the data bytes. After powering for the user to be able to read valid data the conversions must be started. This is realized by sending the command ( 0x8C) with no payload. This command puts the device in read -triggered mode meaning that at the end of every data read transaction (single or multi read) the device starts a new pressure and temperature conversion the data of which can be retrieved at the next read transaction. In case of I2C interface device the readout process for pressure is presented below: In case of an SPI interface device the same pressure readout is presented below: For temperature reading the readout process is identical with different register address (0x44). Also the user can make use of the multi read feature to read both calibrated pressure and calibrated temperature values in one transaction both in I 2C or SPI mode. To realize this transaction the MCU must start reading register (0x40) and not stop after the readout of the calibrated pressure values (4bytes) but continue reading the next 4 bytes. The last 4 bytes are the calibrated temperature value as described in the previous section. If the user performs a read transaction other than reading temperature and pressure data (eg serial number) the conversions automatically stop and need to be restarted from the user. S SLAVE_ADD+ W bit (0x50) A REG_ADDRESS (0x40) A S SLAVE_ADD + R bit (0x51) A DATA 0 A ... DATA n N P START SLAVE ACK SLAVE ACK RESTART SLAVE ACK MASTER ACK MASTER NACK STOP MOSI REG_ADDRESS (0x40) - ... - MISO - DATA 0 DATA n A ll data sheet.com
Serial Number Reading Process Like data readout, serial number readout is the same for both I 2C and SPI interfaces. Unlike data readout the serial number is located at a different memory and the readout process is somewhat different than the data readout. In this case the user must write the 2 byte command (0x238A) to the device after the slave address (0x50). After the command is sent the user can read the 7 bytes of the serial number and translate them as described below: ADDRESS BYTE NAME TYPE DEFAULT VALUE (Hex) MNEMONIC Product Family Code Byte 1 R Fixed ID PFC[7:0] Product Family Code Byte 2 R Fixed ID PFC[15:8] Product code Byte 1 R Fixed ID PC[7:0] Product code Byte 2 R Fixed ID PC[15:8] Lot number R Fixed ID LN [7:0] Serial number 1 R Fixed ID SN[7:0] Serial number 2 R Fixed ID SN[15:8] The serial number consists of 4 parts: [Product Family Code] -[Product Code] [Lot number] - [Serial Number]. For example the serial number 0x8803530104001C translates to: 904 -339 04-0028 S SLAVE_ADD+ W bit (0x50) A OPCODE_LO (0x23) A S SLAVE_ADD + R bit (0x51) A PFC[7:0] A ... SN[15:8] N P OPCODE_HI (0x8A) A START SLAVE ACK SLAVE ACK RESTART SLAVE ACK MASTER ACK MASTER NACK STOP SLAVE ACK A ll data sheet.com
- I2C Interface The sensors obey the full I 2C protocol standard with the difference that they operate up to SCL (I2C Clock) speeds of 100 kHz. The sensors support clock stretching functionality. If the device is not ready to transmit data, holds the clock (SCL) line low and releases it once it is ready. The master must consider this condition and either identify it and wait until the clock is released or exit with a repeated start condition. The sensor can operate with single read or single write transactions as well as multi read transactions. For data readout the multi read transaction is highly recommended as it ensures data integrity. The sensors allow for register address auto increment starting from the first address definition. In order to ensure data integrity when the BMS1 device is connected to a multi -slave I2C bus, the user must drive IntSel pin low when communicating with other devices other than the BMS1. When the user wants to communicate with the BMS1 device he must drive IntSel pin high. I2C Specification Both signals (SCL and SDA) are bidirectional. They are connected via resistors to a positive power supply voltage. This means that when the bus is free, both lines are high. All devices on the bus must have open -collector or open -drain pins. Activating the line means pulling it down. The number of the devices on a single bus is limited to 127 and the only requirement is that the bus capacitance does not exceed 400pF. For each clock pulse one bit of data is transferred. The SDA signal can only change when the SCL signal is low – when the clock is high the data should be stable. Each I2C command initiated by a master device starts with a START condition and ends with a STOP condition. For both conditions SCL has to be high. A high to low transition of SDA is considered as START and a low to high transition as STOP. After the Start condition the bus is considered as busy and can be used by another master only after a Stop condition is detected. After the Start condition the master can generate a repeated Start. This is equivalent to a normal Start and is followed by the slave I2C address. A ll data sheet.com
Microcontrollers that have dedicated I 2C hardware can easily detect bus changes and behave also as I 2C slave devices. However, if the I 2C communication is implemented in software, the bus signals must be sampled at least two times per clock cycle in order to detect necessary changes. Data on the I2C bus is transferred in 8 -bit packets (bytes). There is no limitation on the number of bytes, however, each byte must be followed by an Acknowledge bit. This bit signals whether the device is ready to proceed with the next byte. For all data bits including the Acknowledge bit, the master must generate clock pulses. If the slave device does not acknowledge the trans- fer this means that there is no more data, or the device is not ready for the transfer yet. The master device must either generate Stop or Repeated Start condition. Each slave device on the bus should have a unique 7 -bit address. The communication starts with the Start condition, followed by the 7 -bit slave address and the data direction bit. If this bit is 0 then the master will write to the slave device. Otherwise, if the data direction bit is 1, the master will read from slave device. After the slave address and the data direction is sent, the master can continue with reading or writing. The communication is ended with the Stop condition which also signals that the I 2C bus is free. If the master needs to communicate with other slaves, it can generate a repeated start with another slave address without generation Stop condition. All the bytes are transferred with the MSB bit shifted first. A general I2C communication diagram is shown below: I2C read diagram I2C write diagram A ll data sheet.com
A typical use case is presented bellow. The user powers up the ESCP -BMS1 either by applying power to the system. After initializing, the user reads the device ’s serial number, initiates sensor conversions and reads the pressure and temperature values periodically. If the user reads anything other than calibrated pressure or temperature the conversion start command needs to be sent again. The readout of serial number is optional step but it is essential to clarify that if the user interrupts the sample reading loop the “start conversions ” command must be issued before any attempt to read pressure or temperature. I2C Slave address The sensor is factory programmed with the default 7 bit slave address of 0x28. The end user only needs to program the R/W bit that corresponds to the direction of communication as shown below. 0 1 0 1 0 0 0 R/W MSB LSB Hence for write transactions the salve address byte is 0x50 and for read transactions the slave address byte is 0x51. Slave address is shifted left one and the R/W bit appended. The sensor supports SCL clock frequencies up to 100 kHz. A ll data sheet.com
- SPI Interface The sensor can communicate with two different serial interfaces, I 2C and SPI (only one at the same time). The interface select pin selects which interface is active. Pulling the interface select pin high enables I 2C interface whereas pulling it low enables SPI interface. In this document the SPI interface is described hence the interface select pin must be pulled low to operate in this mode. The sensor obeys the full SPI protocol standard. The SPI specifications are depicted in the following tables. SPI Parameter Description Setting CPOL Clock Polarity 0 CPHA Clock Phase 1 Mode SPI Mode 1 DORD Bit Sequence order 0, MSB SPI Read Transaction SPI Write Transaction A ll data sheet.com
The timing specification of the SPI interface for the device are depicted in the following table: The sensor can operate with single read or single write transactions as well as multi read and multi write transactions. For data readout a multi read transaction is highly recommended as it ensures data integrity. The sensor allows for register address auto increment starting from the first address definition. After the CS change from HI to LOW the master (MCU) should transmit the register address that want to address. After the addressing the BMS1 device will shift the contents of the register addressed at every clock cycle. After the completion of a full byte transfer the BMS1 device will continue to shift the data of the next register thus realizing the auto increment functionality. In the diagram below a transaction example is shown: Timing Parameter Value Units Serial Clock Frequency 1 MHz Serial Clock Pulse width HI state 500 ns Serial Clock Pulse width LOW state 500 ns CS enable-to-valid latch 150 ns CS pulse width between write cycles 500 ns Data setup time prior to clock edge 100 ns Data hold time after clock edge 100 ns Data valid after clock edge 100 ns A ll data sheet.com
A typical use case is presented bellow. The user powers up the ESCP -BMS1 either by applying power to the system. After initializing, the user reads the device ’s serial number, initiates sensor conversions and reads the pressure and temperature values periodically. If the user reads anything other than calibrated pressure or temperature the conversion start command needs to be sent again. The readout of serial number is optional step but it is essential to clarify that if the user interrupts the sample reading loop the “start conversions ” command must be issued before any attempt to read pressure or temperature. A ll data sheet.com
- Analog Interface Similar to the PWM versions the analog version of the BMS1 device outputs an output voltage raging from 0 to Vdd according to the calibrated pressure measured. The output is not buffered so the output is a high impedance signal of several hundreds Kohms and the user must take this in to consideration as the load can distort the signal. The characteristics of the analog output are described in the table below: The pressure output is proportional to the voltage and is calculated from the equation below: Value Unit Vout min 0 V Vout max Vdd V Response time (10%-90%) Depends on specified conversion rate and load capacitance V ripple <10 mV p-p Output impedance 220 kohm A ll data sheet.com
- Mechanical Drawings (mm) Option 11 Option 02 High Side Port Low Side Port A ll data sheet.com
- Mechanical Drawings (mm) Option 15 Option 08 A ll data sheet.com
The ESCP -BMS1 sensor features digital temperature compensation. The temperature is measured on the MEMS element by an on -chip temperature sensor. This data is fed to a compensation circuit that is also integrated on the microprocessor. Thus, no external temperature compensation is necessary. Sensor Handling The ESCP -BMS1 sensor is designed to be robust and shock resistant. Nevertheless, the accuracy of the high -precision ESCP -BMS1 can be degraded by rough handling. ES Systems does not guarantee proper operation in case of improper handling. 19. Instructions of Operation 18. Instructions of Mounting 17. PCB Layout (All dimensions in mm) For optimal performance, ensure that the ESCP -BMS1 sensor is correctly mounted to the PCB as illustrated in the figures above. No mechanical stress should be applied to the sensor during or following its installation. The suggested internal diameter for the tubes is 2.5 mm. Tubing outside PCB Tubing inside PCB A ll data sheet.com
- Ordering Information ESCP-BMS1-N-NNNNNNN-NN-NN-NN-N-N Media G Dry gases only Pressure Range Absolute Gauge Differential 00500MA 00060MG 00010MD 01000MA 00100MG 00050MD 01250MA 00160MG 00100MD 02000MA 00250MG 00150MD 05000MA 00400MG 00200MD 10000MA 00600MG 00250MD 00050KA 01500MG 00500MD 00100KA 05500MG 00750MD 00125KA 07000MG 01000MD 00200KA 11000MG 00001KD 00500KA 00006KG 00005KD 01000KA 00010KG 00010KD 00010PA 00016KG 00015KD 00015PA 00025KG 00020KD 00020PA 00040KG 00025KD 00030PA 00060KG 00050KD 00075PA 00150KG 00075KD 00145PA 00550KG 00100KD 00700KG 00001PD 01100KG 00002PD 00001PG 00003PD 00002PG 00004PD 00003PG 00005PD 00004PG 00006PD 00005PG 00007PD 00010PG 00010PD 00020PG 00015PD 00080PG 00100PG 00160PG Temperature Sensor Y Yes N No Compensated Temperature 01 0oC to 60oC 02 -20oC to 85oC Pressure Port 11 02 15 08 Output Type
01 SPI / I2C (address 0x28) 05 Analog
02 SPI / I2C (address 0x29)
03 SPI / I2C (address 0x2A)
04 SPI / I2C (address 0x2B)
A ll data sheet.com
DO NOT USE these products as safety or emergency stop devices, or in any other application where failure of the product could result in personal injury. Failure to comply with these instructions could result in death or serious injury. WARRANTY ES Systems warrants this Product to be free of defects in materials and workmanship for a period of one (1) year from the date of purchase. Upon examination by ES Systems, if the unit is found to be defective it will be repaired or replaced at no charge. ES Systems' WARRANTY does not apply to defects resulting from any action of the purchaser, including but not limited to mishandling, improper interfacing, operation outside of design limits, improper repair, or unauthorized modification. This WARRANTY is VOID if the unit shows evidence of having been tampered with or shows evidence of being damaged as a result of excessive corrosion; or current, heat, moisture or vibration; improper specification; misapplication; misuse or other operating conditions outside of ES Systems' control. Components which wear are not warranted. ES Systems neither assumes responsibility for any omissions or errors nor assumes liability for any damages that result from the use of its Product in accordance with information provided by ES Systems, either verbal or written. ES Systems warrants only that the parts manufactured by it will be as specified and free of defects. ES SYSTEMS MAKES NO OTHER WARRANTIES OR REPRESENTATIONS OF ANY KIND WHATSOEVER, EXPRESSED OR IMPLIED, EXCEPT THAT OF TITLE, AND ALL IMPLIED WARRANTIES INCLUDING ANY WARRANTY OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR PURPOSE ARE HEREBY DISCLAIMED. No representative of ES Systems is authorized to extend this Warranty or to change it in any manner whatsoever. No warranty applies to any party other than the original Customer. The remedies of the Customer set forth herein are exclusive and the total liability of ES Systems with respect to this order, whether based on contract, warranty, negligence, indemnification, strict liability or otherwise, shall not exceed the purchase price of the component upon which liability is based. In no event shall ES Systems be liable for consequential, incidental or special damages. Specifications may change without notice. The information supplied is believed to be accurate and reliable as of this issue; however, ES Systems assumes no responsibility for its use. ES Systems S.A. Head Office: 7, Stratigi St., GR-154 51 Neo Psychico, Greece Tel: (+30) 210 672 8610, Fax (+30) 210 672 8624 Factory: 57, I.Metaxa str., GR-194 41 Koropi, Greece Tel: (+30) 216 2000 500, Fax (+30) 216 2000 555 Important Notes A ll data sheet.com